Basic function principles
The EL66xx Ethernet Switchport terminals have 2 different operating modes, ideal for the tasks required for Ethernet connectivity. The two operating modes, which can be active simultaneously, provide both the real-time-critical transmission and reception of configured network variables as well as the transport of standard Ethernet traffic, which, while it is not real-time-critical, does involve large data flows using, for instance, the IP protocol:
- Real-time data exchange: Publisher/subscriber, Beckhoff network variables, EtherCAT Automation Protocol
The TwinCAT configuration file *.tsm configures an EL66xx when EtherCAT starts up with CoE parameters in such a way that it - transmits, as the publisher, data delivered through the cyclical data transfer in the real-time cycle.
- transmits subscribers received in the same way to the EtherCAT Master over the cyclical EtherCAT data exchange.
Cyclical data exchange with the EL66xx is configured in the PDO settings of the EL66xx when EtherCAT starts up, and cannot be changed online. - Non-real-time data exchange
In parallel with this, the EL66xx can transfer Ethernet frames through the acyclic mailbox exchange (EoE = Ethernet over EtherCAT) between the terminal and the EtherCAT Master/TwinCAT. This data exchange is optimized for throughput, and may involve automatic fragmentation - by default, all telegrams that are not transferred in the PDO context are transported through the acyclic channel by means of EoE.
The flow of data in the EL66xx can be represented schematically as follows:
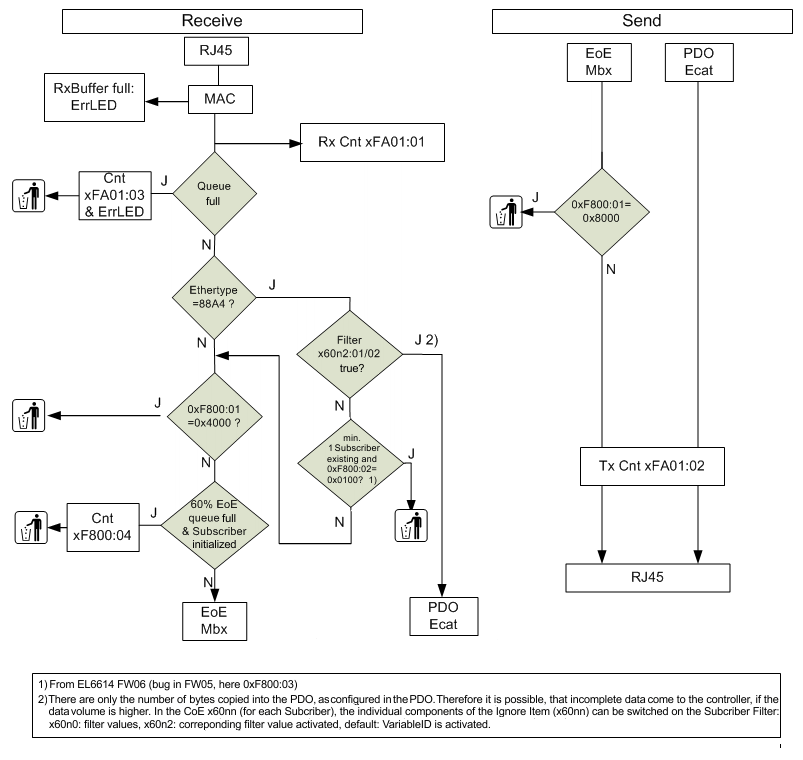 Fig.6: EL66xx data diagram
The EL6601/EL6614 cannot transport an EtherNet Industrial Protocol (EtherNet/IP).
Diagnostics
Online diagnostics
The following objects are available for initial diagnostic in the CoE directory:
- 0xFA01, subindex 01: Frame Counter Rx (incoming to RJ45 socket).
- 0xFA01, subindex 02: Frame Counter Tx (outgoing from RJ45 socket).
The values can be read from the controller using PLC function blocks (FB_EcCoeSdoRead in TcEtherCAT.lib).
This and further diagnostic information from the CoE of the EL66xx are accessible via this sample PLC block  .
Error LED
The red Error LED lights up 250 ms in the event of
- Ethernet Receive Overrun --> in general, more Ethernet frames are received at the RJ45 connection than can be transported away via EtherCAT (PDO or mailbox). The telegrams are discarded.
- Ethernet EoE Overrun --> more non-real-time frames are being received at the RJ45 connector than can be transported away by EtherCAT/EoE The data are discarded.
- Ethernet Frame Error
If the occurrence of an overrun causes data to be lost, higher protocol layers in an Ethernet network are responsible for repeating the transmission.
 | Overruns The following measures can be used to counter overruns:
|
Cable redundancy
If the EL66xx is operated in a system with cable redundancy, please keep the following in mind:
- real-time operation with network variables is possible
- in the event of non-real-time operation with IP transfer the IP traffic is routed via the primary EtherCAT port. Therefore the Windows IP settings of this port are also used.
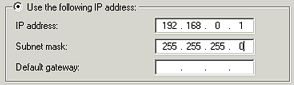 Fig.7: IP settings EtherCAT port
If there is no longer a link to this port, from Windows under TwinCAT 2 or 3 there is also no IP communication to this port currently.
For this reason, do not let the Ethernet connection between the primary EtherCAT port and the first EtherCAT slave fail, since otherwise IP communication is no longer possible via the EL66xx.
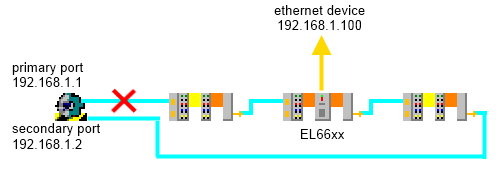 Fig.8: Connection failure between primary EtherCAT port and 1st slave (X)