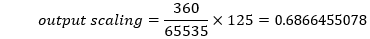Configuration of the TwinCAT NC
The TwinCAT NC can be configured by parameters. A complete description of the parameters of the TwinCAT NC can be found in the Documentation of the TwinCAT functions TF50x0 or on our website: https://www.beckhoff.de/tf5000.
Set the following parameters carefully:
Basic unit
This setting defines the units of the parameters of the axis.
You can find this setting at:
NC Axis > "Settings" tab > drop-down menu "Unit".
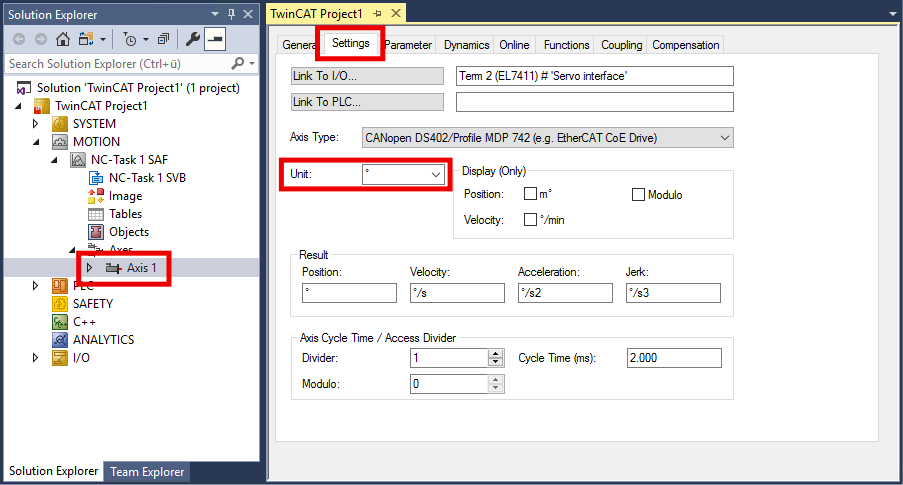
- For rotary movements, select ° or "Degree".
- For linear movements, select mm or m.
Reference velocity and maximum velocity
You can find these parameters at:
NC Axis > "Parameters" tab > "Reference Velocity" and "Maximum Velocity"
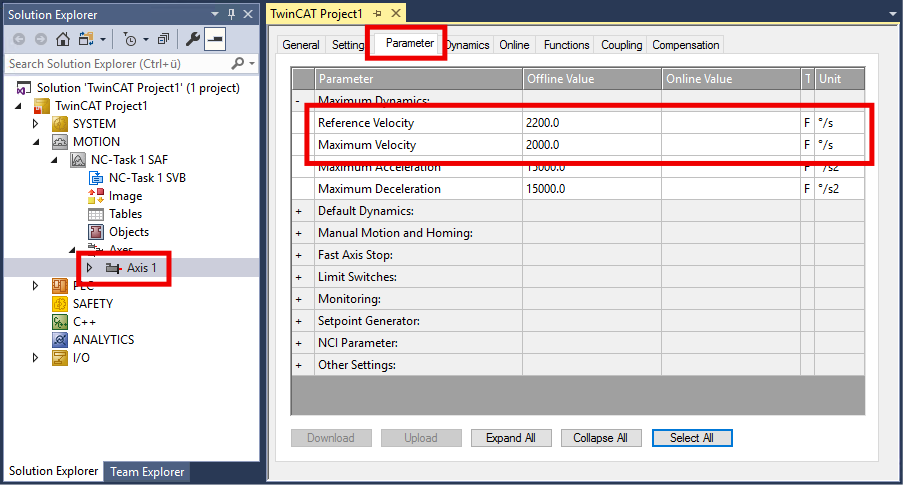
Recommendation: enter the rated speed or rated velocity for the "Reference Velocity".
Dynamics
You can find the dynamics parameters at:
NC Axis > "Dynamics" tab
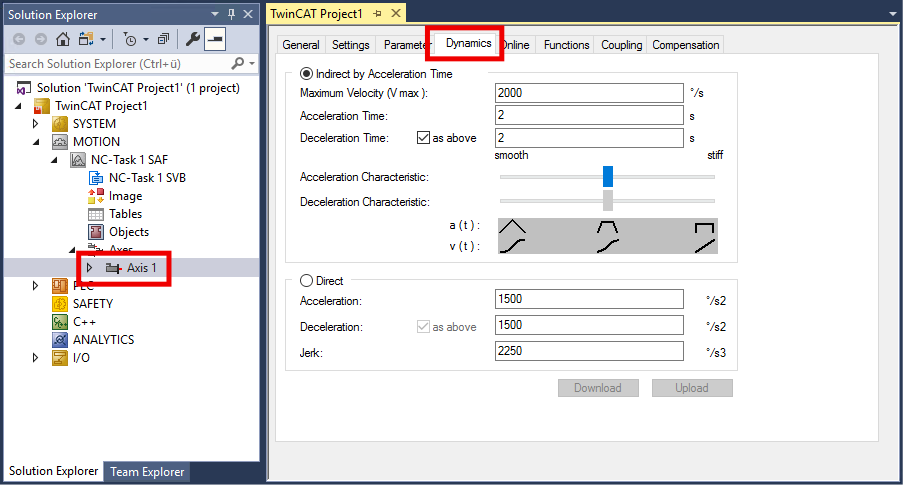
Set the acceleration time and deceleration time: "Acceleration Time" and "Deceleration Time".
Select the ramp curve using the sliders.
Encoder scaling factor for rotary axes
You can find these parameters at:
NC Axis > "Enc" > "Parameters" tab
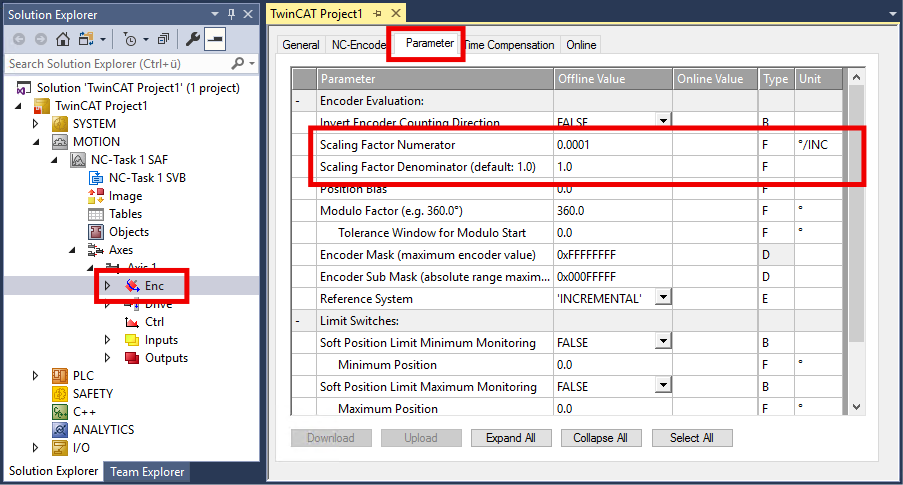
The encoder scale factor is specified as a fraction. There is a parameter for the numerator and a parameter for the denominator.
- Numerator: "Scaling Factor Numerator"
- Denominator: "Scaling Factor Denominator"
The value for the encoder scaling factor depends on whether you are using an incremental encoder:
- For operation with an incremental encoder:
- "Scaling Factor Numerator": 360°
- "Scaling Factor Denominator": The resolution of the incremental encoder multiplied by a factor of four.
Unit: Increments per revolution.
Example with 1024 increments: 1024 x 4 = 4096 - For operation without incremental encoder:
- "Scaling Factor Numerator": 360°
- "Scaling Factor Denominator": 65536
Encoder scaling factor for linear axes
- "Scaling Factor Numerator": 1 mm
- "Scaling Factor Denominator":
- Convert the resolution of the incremental encoder to Inc/mm.
- Multiply the resolution by a factor of four.
- Enter the result in the parameter "Scaling Factor Denominator".
Example:
The resolution of the incremental encoder is specified as 512 Inc / (2 mm). This corresponds to 256 Inc / mm.
For the "Scaling Factor Denominator", enter: 256 x 4 = 1024.
Output scaling for velocity
You can find this parameter at:
NC Axis > "Drive" > "Parameters" tab
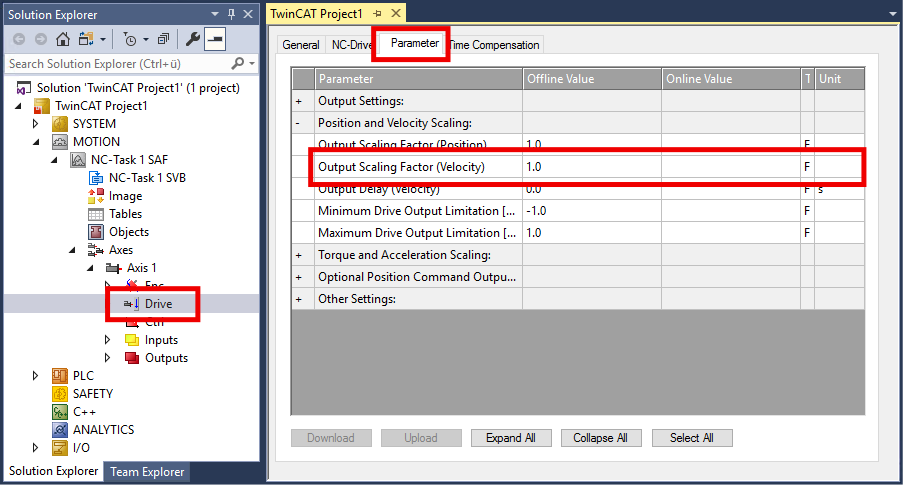
The output scaling of the velocity is only relevant for the CSV operation mode.
The calculation depends on whether you are using an incremental encoder:
- For operation with an incremental encoder:
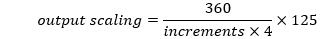
Example: for an encoder with 1024 increments per revolution, the output scaling is 10.98632813. - For operation without incremental encoder: