Position controller
In Position controller mode, the EL70x7 operates in the cyclical position interface. A defined position can be set via the STM Position variable.
Notes
- This mode can be used with a connected encoder or with the internal counter (without encoder).
- The process data can be transferred with TwinCAT NC or directly from the PLC (Positioning interface).
- Third-party motors are supported
Step by Step
- Add the terminal to the configuration as described in the section TwinCAT configuration settings – manual or – Online scan.
- Link the terminal with the NC as described in section Integration into the NC configuration (if TwinCAT NC is used).
- Configure the EL70x7
- automatically - import the XML motor file into the startup directory as described in section Settings in the CoE - automatic.
- manually - configure the parameters as described in section Settings in the CoE - manual.
- Set the operating mode in the CoE directory to Position controller, Fig. "Position controller mode".
- Under Predefined PDO Assignments select Position control, Positioning interface compact, Positioning interface or Positioning interface with info data , Fig. "Predefined PDO Assignment: Position control".
- Activate the configuration (Ctrl+Shift+F4).
- Run through the State Machine of the terminal. Here you have two options.
- If you use the TwinCAT NC.
The State Machine is run through automatically by the NC. You can enable the axis in the "Online" tab of the axis.
Tick all options and set override to 100% (see Fig. "Enabling the axis in the NC"). The axis is then ready. - If you don’t use the TwinCAT NC.
In this case you must run through the State Machine manually. Set the variable 0x7010:01 Enable to 1 (TRUE), Fig. "Enabling the axis manually". - A defined position can be entered via the cyclic variable STM Position (Fig. "Entering the position").
The position is specified in increments and depends on the selected feedback (index 0x8012:0A). For an AS10xx motor with internal counter, 12,800 (64-fold Microstepping * 200 full steps of the AS10xx motor) corresponds to one full turn. With an external encoder the value depends on the encoder. For an AS10xx motor encoder with 1024 INC/revolution, 4,096 (1024 INC/rev * 4-fold evaluation) corresponds to one full turn.
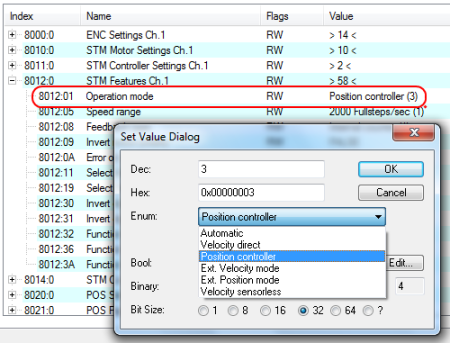 Fig.191: “Position controller” mode
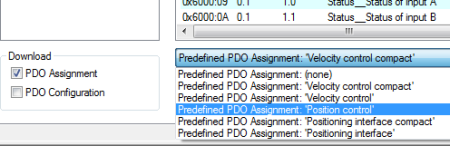 Fig.192: Predefined PDO Assignment: “Position control “
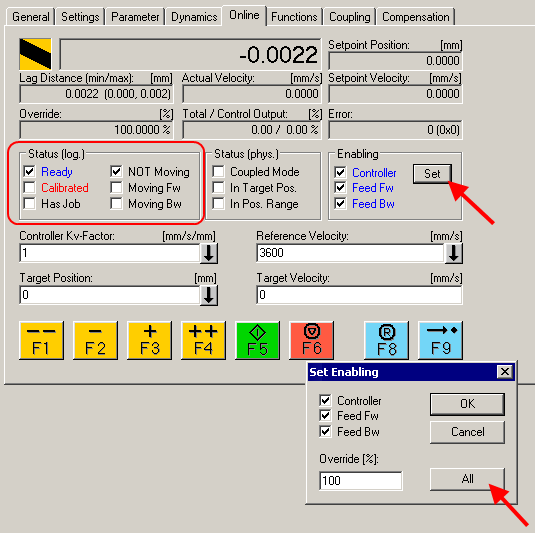 Fig.188: Enabling the axis in the NC
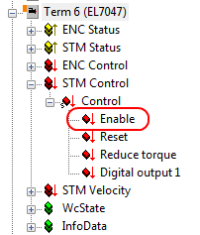 Fig.189: Enabling the axis manually
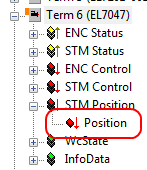 Fig.195: Entering the position