Parameterization
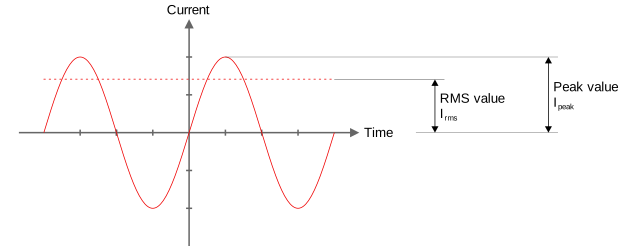
 | Enter alternating current data as peak values
All alternating current data must be entered as peak values.
|
Motor parameters
Set the following parameters according to the specifications in the motor data sheet:
- 0x6075:0 "Motor rated current Ch.1": rated current in [mA] as peak value
- 0x2003:11 "Max current": maximum current in [mA] as peak value
- 0x2003:2E "Rated speed" rated velocity in [rpm]
- 0x2003:13 "Motor pole pairs": the number of pole pairs of the motor
If the number of pole pairs of the motor is unknown, leave the parameter at the default value 1. The actual motor speed is then reduced by the factor "number of pole pairs" compared to the default.
After commissioning, you can determine the number of pole pairs experimentally, see chapter Determine number of pole pairs.
Further parameters
- 0x2002:64 set "Commutation type" to "Sensorless FOC with forced startup".
- DC link settings in CoE object 0xF800
NC scaling factors
- Position values
Default: 0x100000 = 1048576dec increments = 1 revolution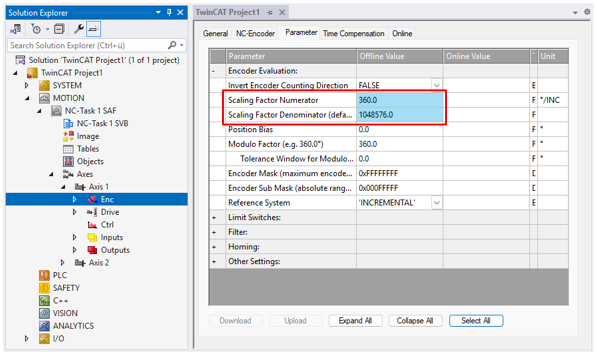
- Velocity values
Default: 268435 increments = 1 revolution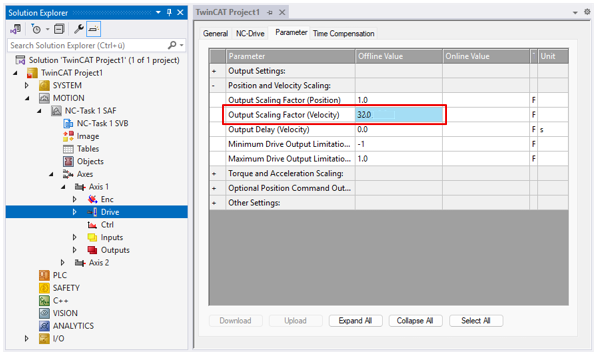
- Torque values
Default: 1000 increments = rated motor current