MDP742 process data
Table of contents |
|---|
Sync Manager (SM)
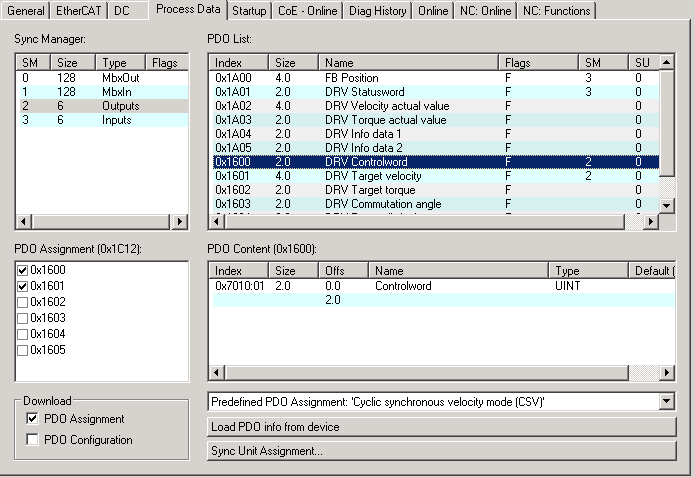
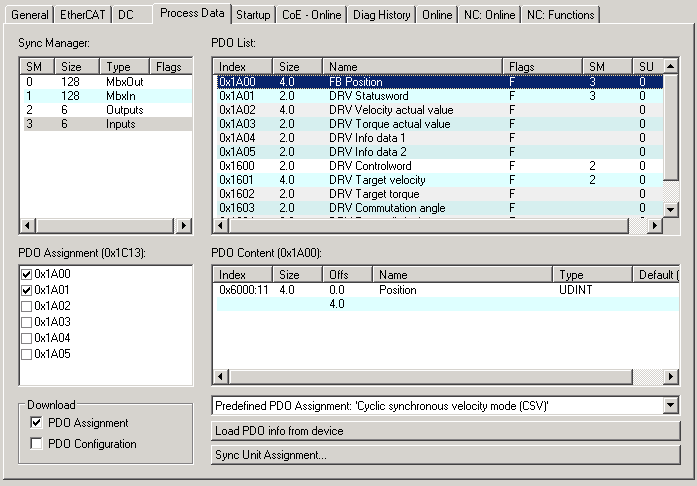
Sync Manager (SM) The scope of the offered process data can be changed via the "Process Data" tab (see Fig. "Process Data tab SM2, EL72x1 (default), Process data tab SM3, EL72x1 (default)").
PDO Assignment
- In order to configure the process data, select the desired Sync Manager (SM2 and SM3 can be edited) in the upper left-hand "Sync Manager" box (see fig.).
- The process data assigned to this Sync Manager can then be switched on or off in the “PDO Assignment” box underneath.
- Restarting the EtherCAT system, or reloading the configuration in configuration mode (F4), causes the EtherCAT communication to restart, and the process data is transferred from the terminal.
PDO assignment of sync managers, EL72x1
SM2, PDO assignment 0x1C12 | |||
|---|---|---|---|
Index | Size (byte.bit) | Name | PDO content |
0x1600 (default) | 2.0 | DRV Controlword | Index 0x7010:01 |
0x1601 (default) | 4.0 | DRV Target velocity | Index 0x7010:06 |
0x1602 | 2.0 | DRV Target torque | Index 0x7010:09 |
0x1603 | 2.0 | DRV Commutation angle | Index 0x7010:0E |
0x1604 | 2.0 | DRV Torque limitation | Index 0x7010:0B |
0x1605 | 2.0 | DRV Torque offset | Index 0x7010:0A |
0x1606 | 4.0 | DRV Target position | Index 0x7010:05 |
SM3, PDO Assignment 0x1C13 | |||
|---|---|---|---|
Index | Size (byte.bit) | Name | PDO content |
0x1A00 (default) | 4.0 | FB Position | Index 0x6000:11 |
0x1A01 (default) | 2.0 | DRV Statusword | Index 0x6010:01 |
0x1A02 | 4.0 | DRV Velocity actual value | Index 0x6010:07 |
0x1A03 | 2.0 | DRV Torque actual value | Index 0x6010:08 |
0x1A04 | 2.0 | DRV Info data 1 | Index 0x6010:12 |
0x1A05 | 2.0 | DRV Info data 2 | Index 0x6010:13 |
0x1A06 | 4.0 | DRV Following error actual value | Index 0x6010:09 |
Predefined PDO Assignment
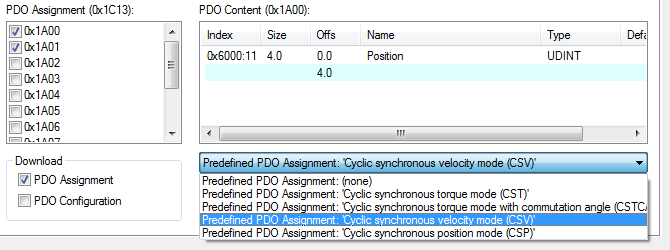
The "Predefined PDO Assignment" enables a simplified selection of the process data. The desired function is selected on the lower part of the "Process Data" tab. As a result, all necessary PDOs are automatically activated and the unnecessary PDOs are deactivated.
Four PDO assignments are available:
Name | SM2, PDO assignment | SM3, PDO assignment |
|---|---|---|
Cyclic synchronous | 0x1600 (DRV Controlword) 0x1601 (DRV Target velocity) | 0x1A00 (FB Position) 0x1A01 (DRV Statusword) |
Cyclic synchronous | 0x1600 (DRV Controlword) 0x1602 (DRV Target torque) | 0x1A00 (FB Position) 0x1A01 (DRV Statusword) 0x1A03 (DRV Torque actual value) |
Cyclic synchronous | 0x1600 (DRV Controlword) 0x1602 (DRV Target torque) 0x1603 (DRV Commutation angle) | 0x1A01 (DRV Statusword) |
Cyclic synchronous | 0x1600 (DRV Controlword) 0x1606 (DRV Target position) | 0x1A00 (FB Position) 0x1A01 (DRV Statusword) 0x1A06 (DRV Following error actual value) |